AuraZex Cybernetic Prototype Arm
Created today
Description
A modular, FDM-optimized cybernetic prototype arm. Designed as a small-scale proof of concept for the AuraZex platform, this model is fully articulated with mechanical pivot joints, internal routing cavities, and removable maintenance panels.
All components are laid out flat on the build plate for independent printing and subsequent physical assembly using the included printed pins.
Prototype Specs
- Shoulder Base: 34×34×26 mm footprint, fixed mount
- Upper Arm Shell: 65 mm length, hollow core for a future SG90-sized servo
- Forearm Shell: 55 mm length, hollowed for wire routing
- Manipulator: Hinged palm with dual 2-link mechanical fingers
- Hardware: Assembles using the provided 4mm printable pins (or substitute with M4 hardware for extra durability)
- Access: 3mm thick removable service panels with alignment pegs
Images
More like this
Explore more in Automotive, RC & Hobby →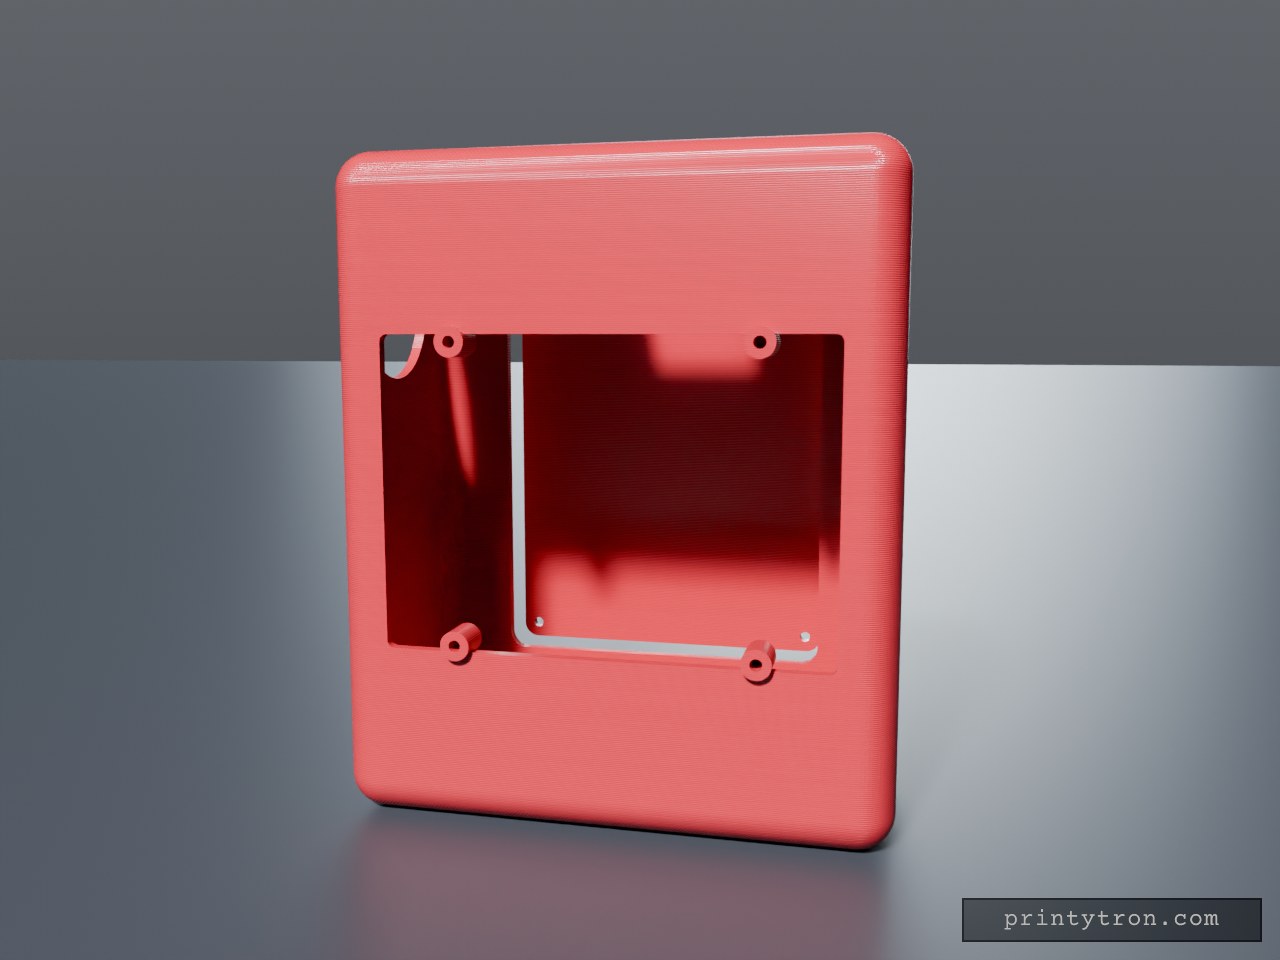
AuraZex 150mm Prototype Torso
Central torso shell for the small-scale AuraZex school prototype. Designed to accept the 30x30mm neck socket from the head unit and features mechanical shoulder mounts on the upper sides. Mating Surfaces Bottom: Carries the exact 4x M5 bolt pattern and dual 12mm wiring pass-throughs to bolt straight onto the AuraZex Waist Bracket. Top: 32x32mm socket providing 1mm clearance for the 30x30mm head connector. Front: Proportionally scaled 120x84mm landscape recess for the tablet, with a central wiring pass-through. Rear: Removable service panel secured by four M3 screws. Prints in FDM with 3mm structural walls and internal component standoffs already placed on the inner front face.
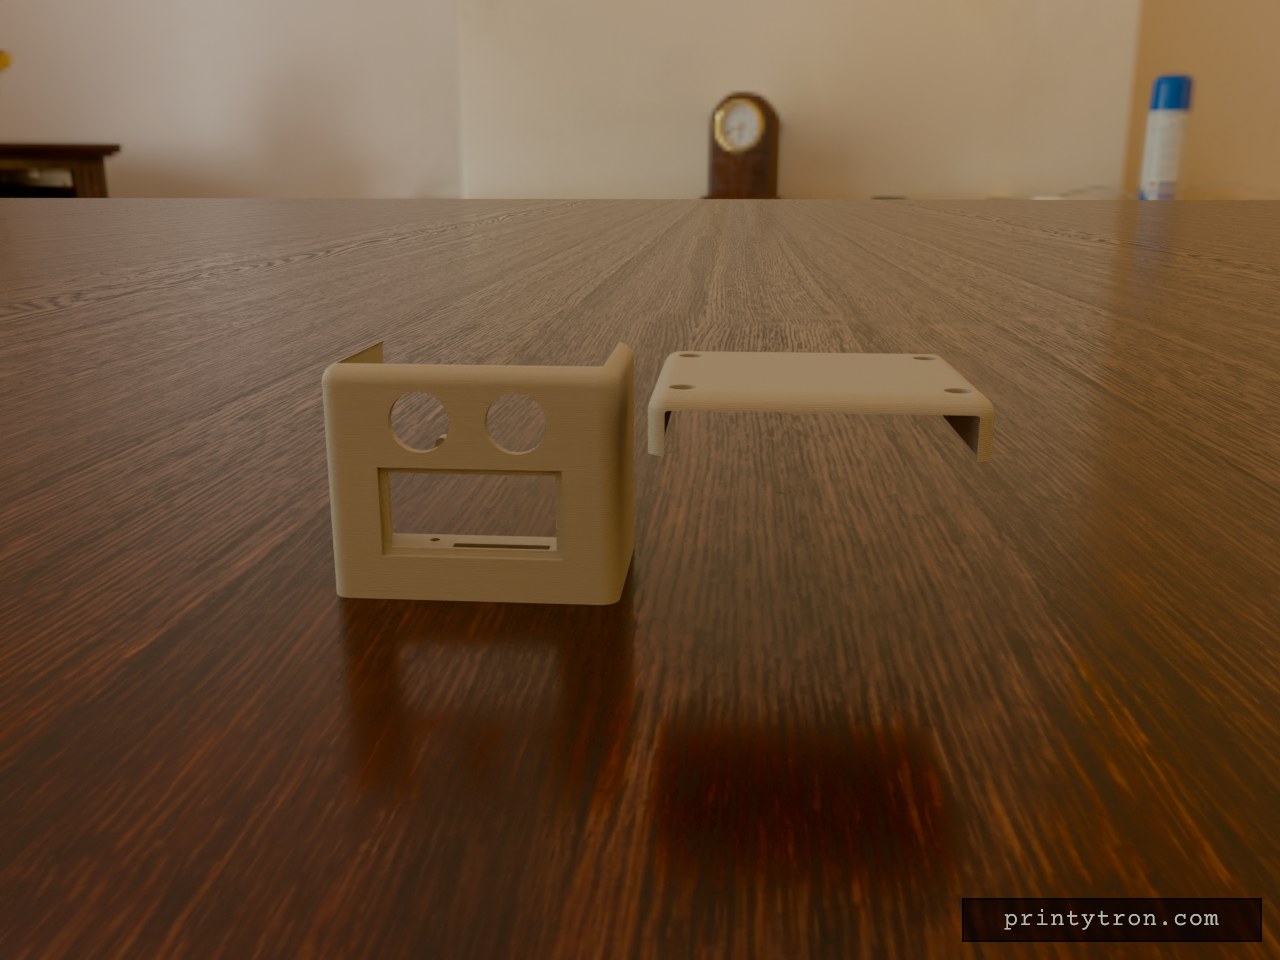
HC-SR04 & M3 Robot Head Prototype
The main sensor and display housing for the AuraZex prototype. Built in two halves for flat-on-bed FDM printing, the front shell handles all structural mounting while the rear acts as a removable service panel. Interface Checklist Sensors: Dual 16.5mm bores on 26mm centers (fits standard HC-SR04 ultrasonic modules). Display: 50x25mm recess with an integrated 2mm interior lip (46x21mm through-hole) to seat a rigid screen. Base Mount: 30x30mm rectangular feed-through, surrounded by an M3 four-hole bolt pattern (44x36mm spacing). Shifted off-center to clear the split line. Assembly: Two integrated 4mm alignment pins. Requires four M3x15mm screws to fasten the rear service panel. Verify your neck bracket matches the 44x36mm M3 pattern before printing.
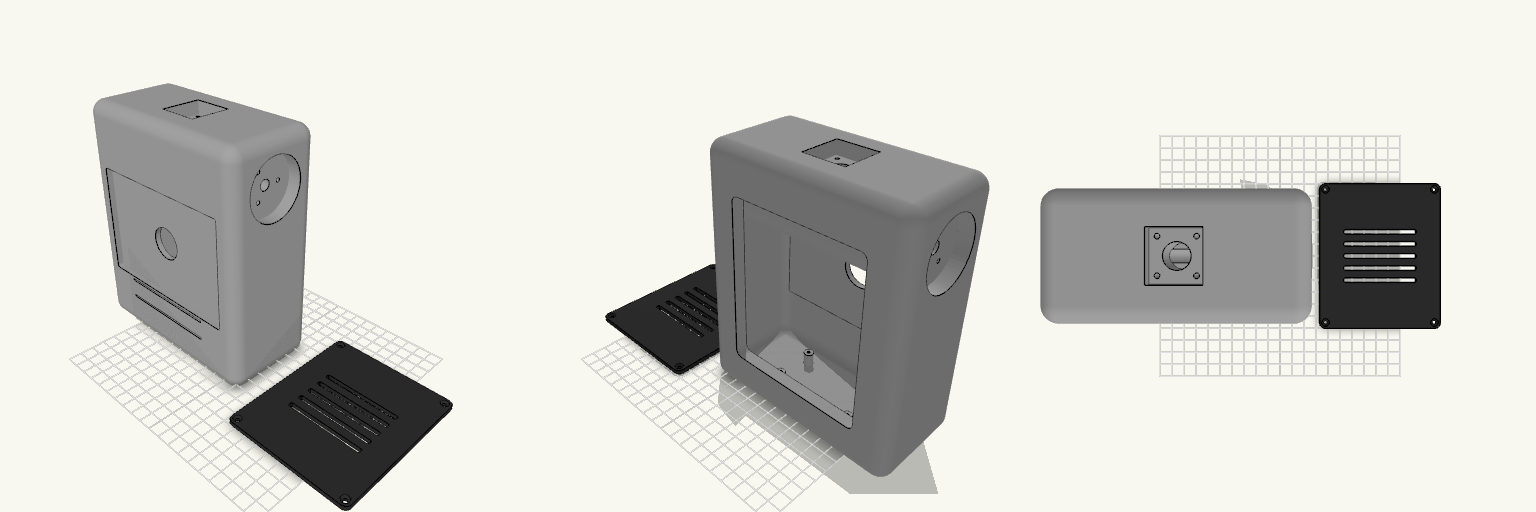
AuraZex 30mm Neck / Torso Chassis
A central chassis block serving as the core of a small-scale AuraZex prototype. Designed to integrate directly with the standard 30×30 mm neck joint and provide mechanical anchor points for articulated shoulder assemblies. The front interface incorporates a precision recess scaled precisely to 50% (120×84 mm) of the full-size AuraZex chest tablet, keeping the prototype mathematically proportional while offering an exact fit for half-scale mockups. Fitment Specifications Neck Interface: 31.5 × 31.5 mm clearance pocket (10 mm depth) with a 22 mm square bolt pattern. Shoulder Sockets: 46 mm diameter flat mating faces. Accepts an 8 mm central axle with a three-point (3.2 mm) indexing circle at a 12 mm radius. Service Access: Removable vented rear panel secured by four M3 fasteners into a continuous recessed lip. Internal Capacity: Generous hollow routing cavity bridging the neck base, the chest screen recess, and four internal floor standoffs for rapid electronics integration.
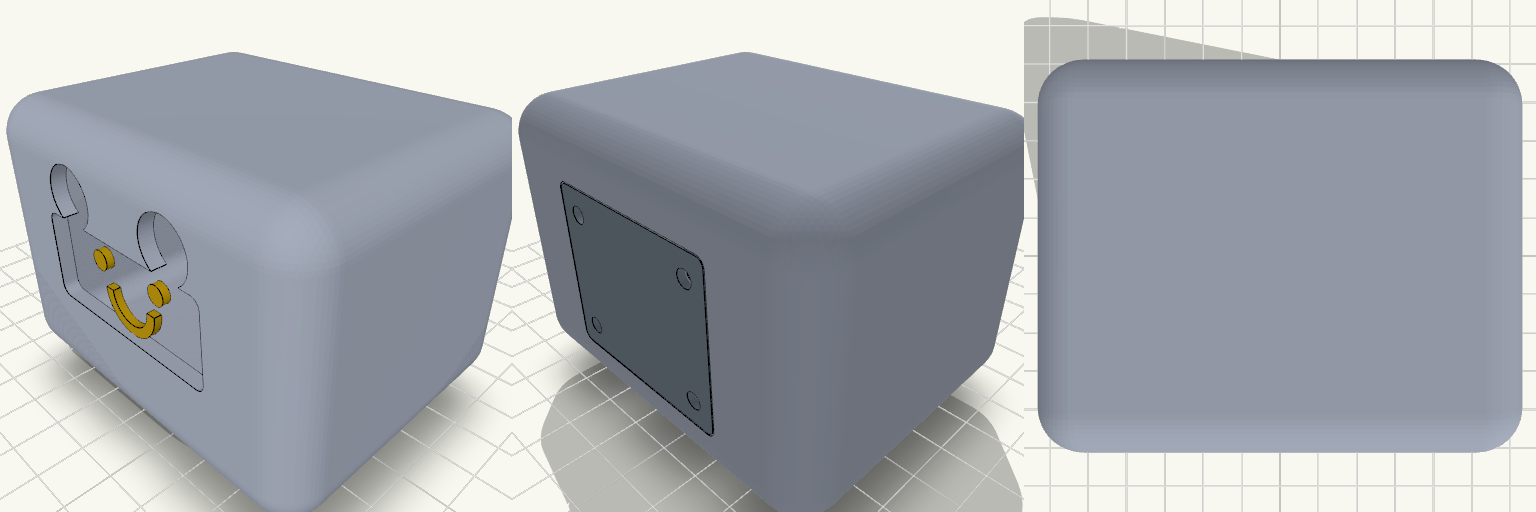
Friendly Robot Companion Head
A compact, friendly robot head prototype featuring a recessed smile display and twin ultrasonic sensor ports. Designed for small-scale desktop companions and educational robotics. Hardware Integration Sensors: Sized for standard HC-SR04 ultrasonic modules. Access: Rear service panel secured with four M3 screws for internal wiring. Mounting: 30 mm neck base with twin anchoring screws.
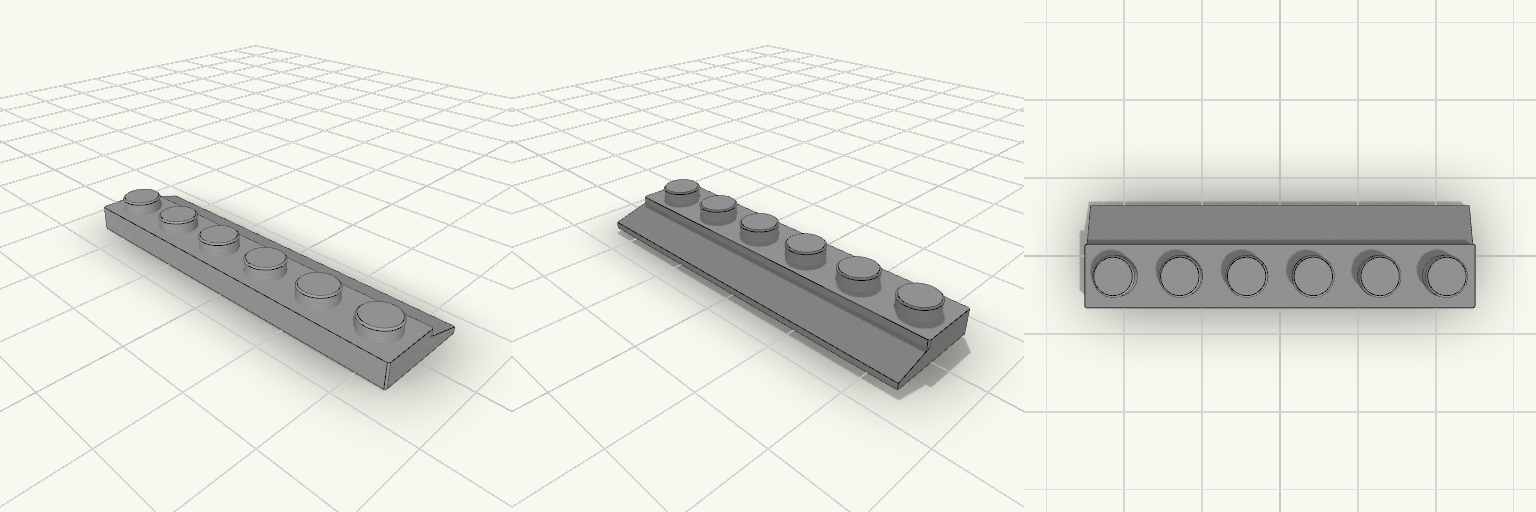
Lego piece for wagon door runner with thinner teeth bit slightly smaller
Wagon door runner to replace 3 off 15208 bricks Version with slightly too large slope
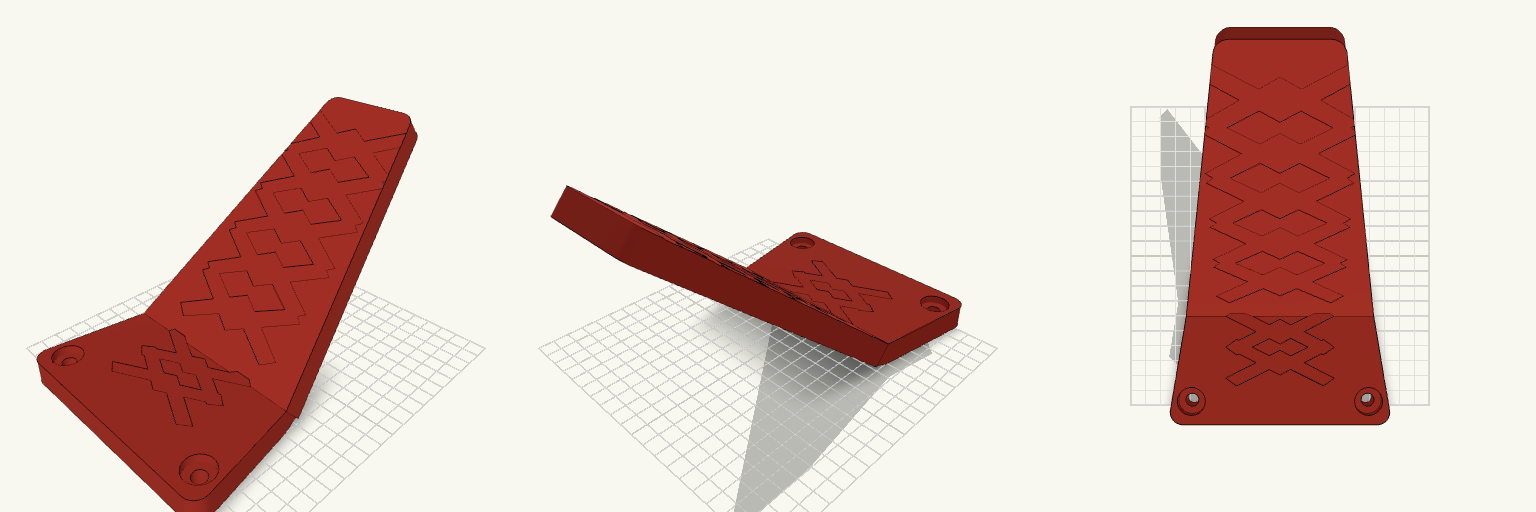
Ethan
What it's for A custom rear foot pedal for the Escoone W6 electric scooter, heavily inspired by the KuKirin G2 profile. It features an aggressive 40-degree kicktail to lock your back foot in place and a shallow 0.2mm intersecting arrow pattern for grip without compromising structural strength. Dimensions Mounting: 2x M8 holes spaced exactly 4.5 inches (114.3 mm) apart. Deck Length: 180 mm of standing space. Kicktail: 40-degree upward sweep. Thickness: 15 mm solid body for PETG printing.